


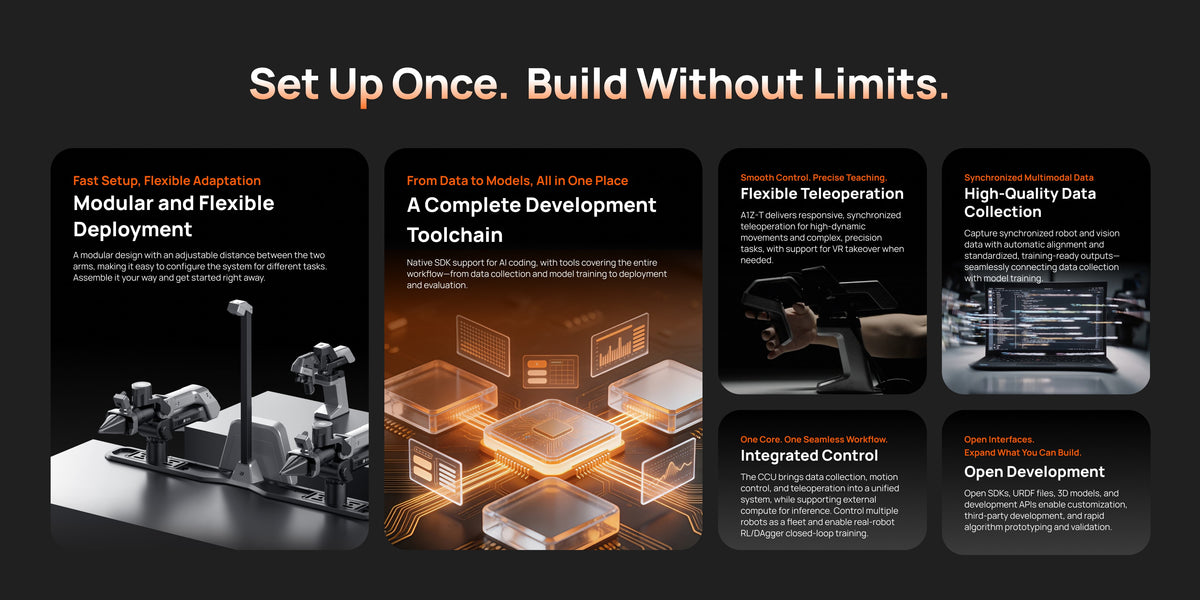
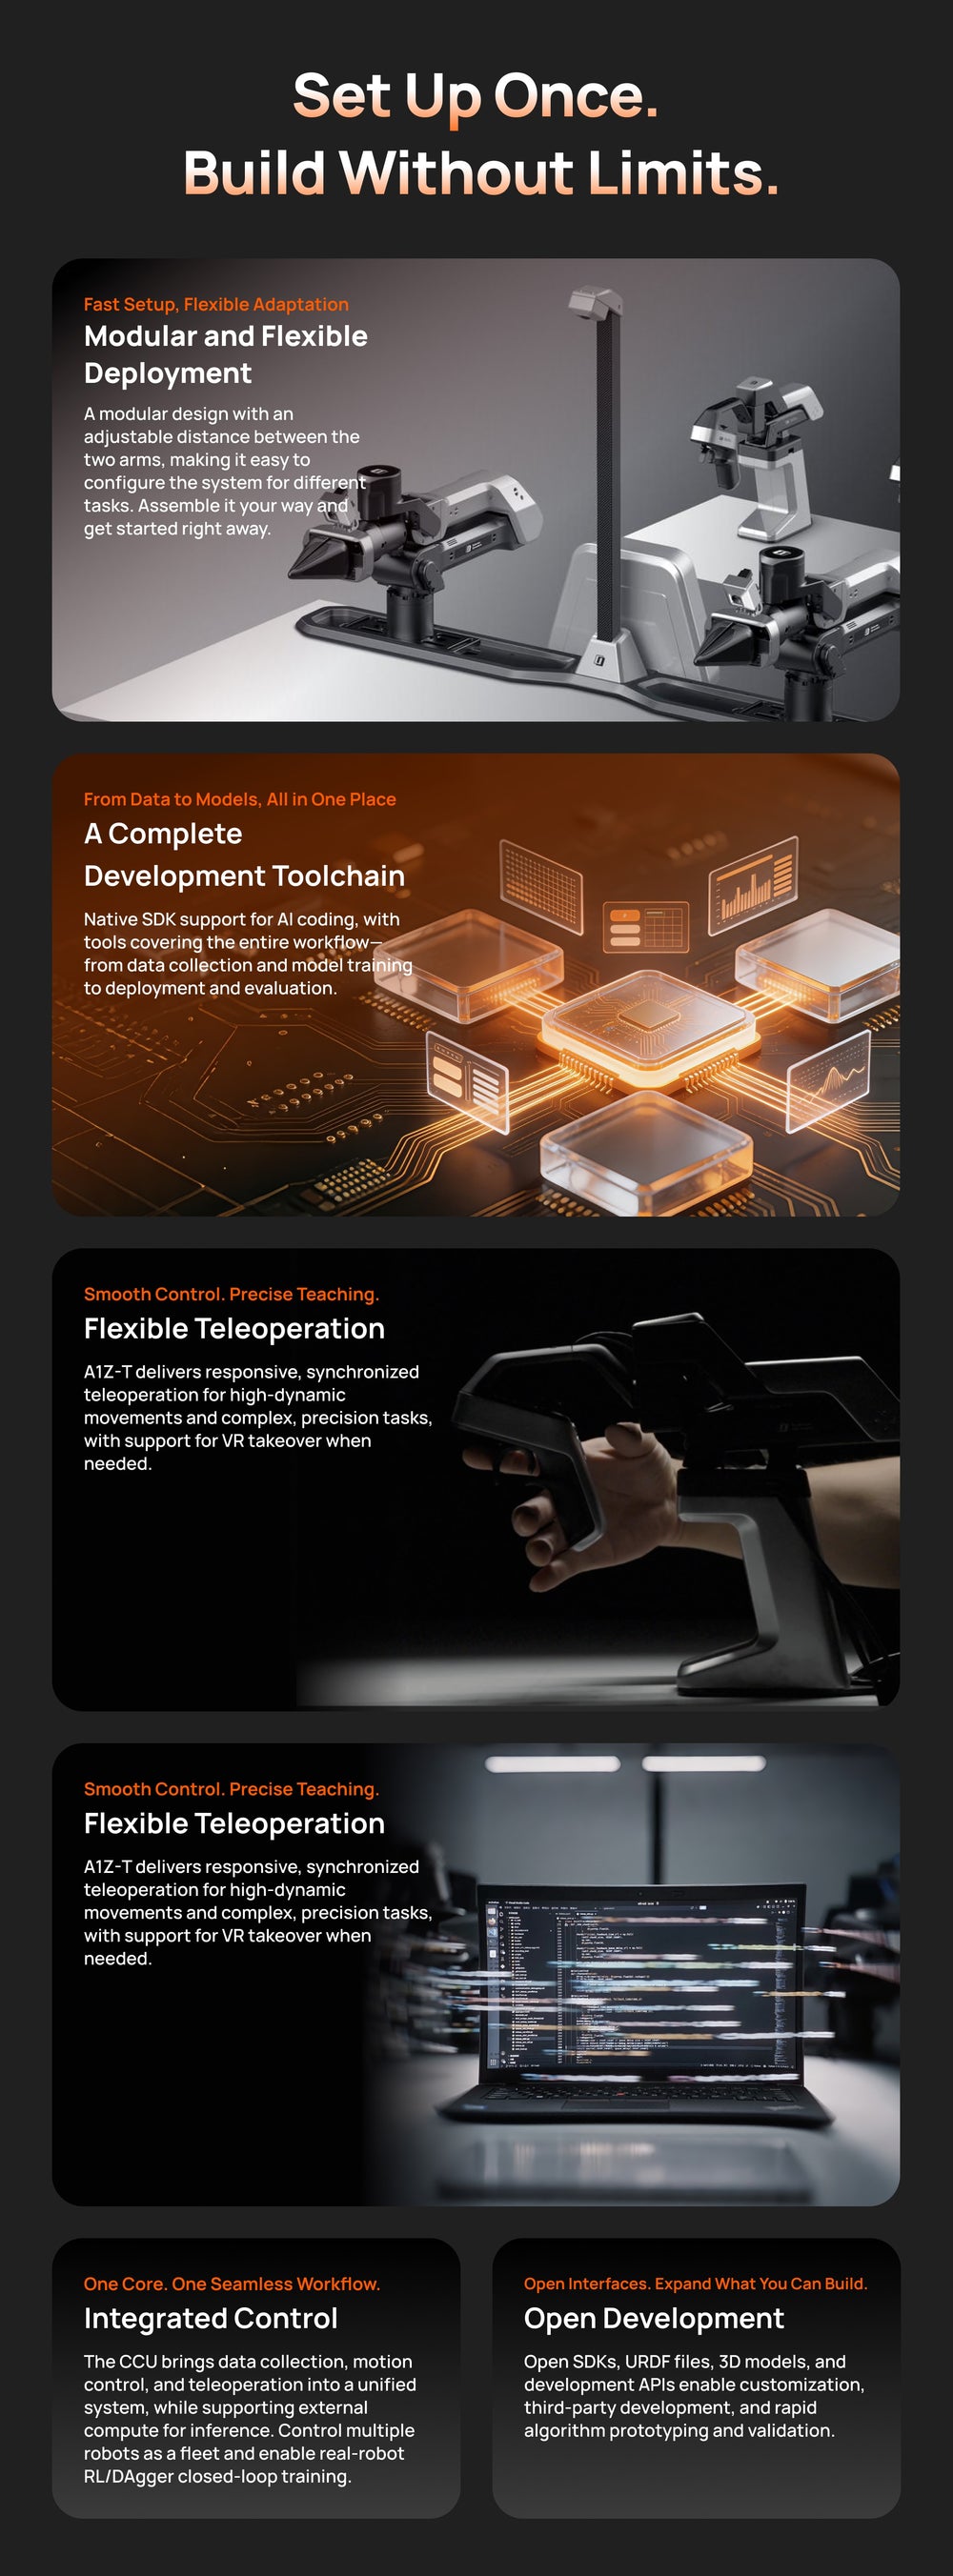


模块化灵活部署: 采用模块化设计,双臂间距可灵活调节,轻松适配不同任务需求。按需组装,快速部署,即刻开启开发。
完整的开发工具链: 原生支持 AI Coding,提供覆盖全流程的开发工具,贯通数据采集、模型训练、部署与评估。
灵活遥操作: A1Z-T 响应灵敏、双臂动作同步,可应对高动态运动及复杂精细操作任务,并支持按需切换 VR 接管。
高质量数据采集: 同步采集机器人状态与视觉数据,自动完成数据对齐,并输出标准化、可直接用于训练的数据,打通从数据采集到模型训练的完整链路。
一体化控制: CCU 将数据采集、运动控制与遥操作整合于统一系统,并支持通过外部计算设备进行模型推理。支持多机器人集群控制,以及基于真实机器人的强化学习(RL)与数据集聚合(DAgger)闭环训练。
开放开发生态: 开放 SDK、URDF 文件、3D 模型及开发 API,支持个性化定制、第三方开发,以及算法的快速原型开发与验证。
可选(A1Z-T 遥操作机械臂/ LEMO 航空箱)
您的订单通常会在14个工作日内发出。我们将尽快为您处理并寄出订单。订单发货后,您将收到一封包含进一步信息的电子邮件。国际订单预计在20至45个工作日内送达。具体送达时间因地区而异。
如需技术支持,请联系 support@galaxea-ai.com 以获取进一步帮助。
Flexible Assembly & Deployment
The modular design allows flexible adjustment of the spacing between the two arms, adapting to different task requirements. Ready to use out of the box.
Complete Development Toolchain
With AI Coding and a native SDK, the development toolchain covers the entire workflow from data collection and model training to deployment and evaluation.
Flexible Teleoperation (Optional)
A1Z-T delivers smooth, responsive teleoperation under highly dynamic conditions, supporting complex and precision-intensive tasks and VR takeover.
Integrated Control
The CCU integrates data collection, motion control, and teleoperation, with support for external computing for inference.
Open Development
Open SDK, URDF, 3D models, and development interfaces support secondary development and algorithm validation.

Research
Embodied AI, Imitation Learning, Robot Manipulation.

Data
Real-World Robot Data Collection & Model Training.

Validation
Rapidly Validate Algorithms, Models, and Robot Tasks.

Innovation
Dual-Arm Coordination, Interaction Experiments.
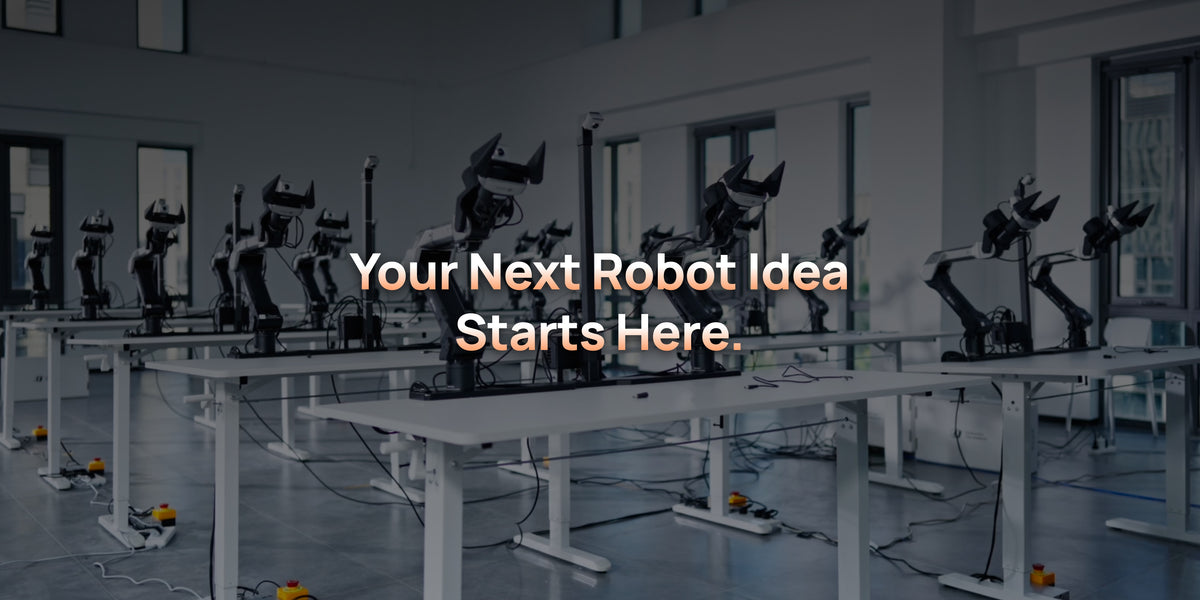
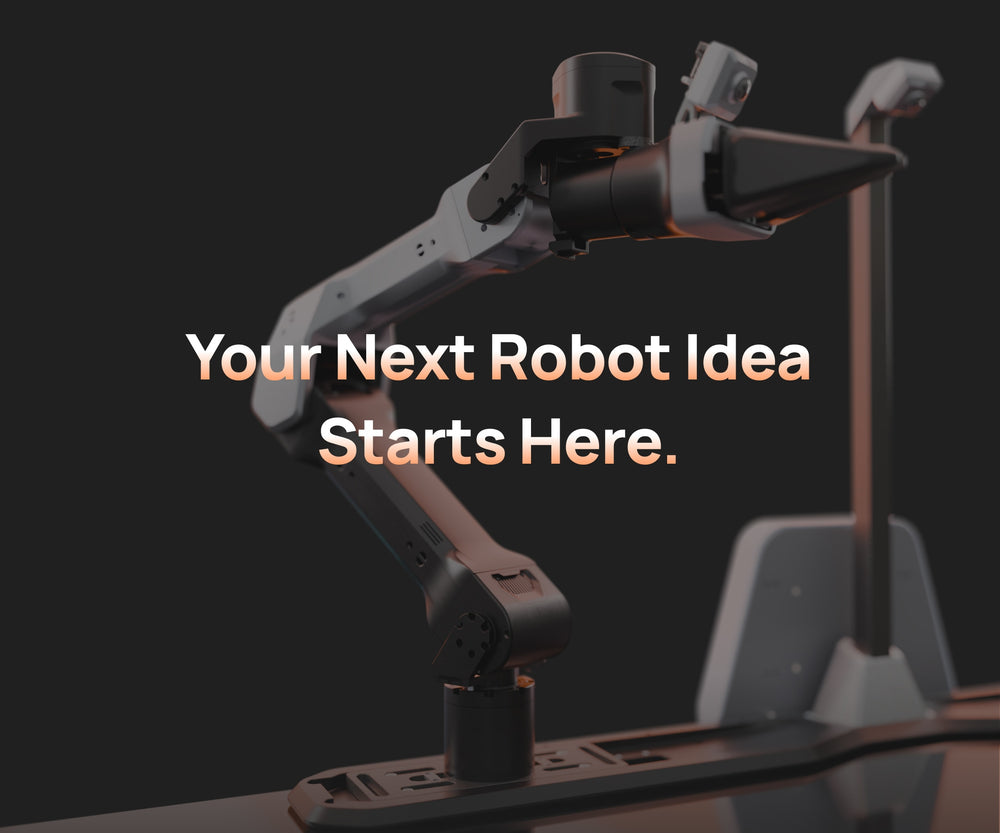
LEMO Dual-Arm Desktop Operation Platform
A1Z-T Teleoperation Arm (Optional)
G1Z Gripper (Optional)
For more detailed information, please visit our GitHub repository. → userguide-A1Z
A1Z provides an SDK natively designed for AI coding, with APIs and code that enable AI coding tools like Cursor, Claude Code, and Copilot to understand the robotics platform and generate accurate robot control code directly—dramatically reducing the need for manual glue code.
A repeatability of 0.1 mm is a widely accepted benchmark for lightweight robotic arms, providing a level of performance and precision that can broadly meet the development needs of most users.
Specific development requirements, including algorithm and model deployment, need to be handled by users on their own host computers. A1Z focuses on providing cost-effective, ready-to-use, all-in-one hardware solutions for the execution side. We also plan to build a developer ecosystem platform to support the sharing and distribution of demos developed with A1Z robotic arms. Stay tuned.
The spacing between the two screw holes is 25 mm. The hole depth from the housing surface is 10 mm, with a maximum safe thread depth of 8 mm.
Lower the Barrier. Build More.
A1Z is committed to making robot development more accessible by continuously expanding our developer tools and software stack. From traditional robotics development—including motion control and robot operation—to Embodied AI algorithms and model development, our platform is designed to support the full development workflow.
Our AI Coding–Native SDK is one example. A1Z provides an SDK natively designed for AI coding, with APIs and code that enable AI coding tools such as Cursor, Claude Code, and Copilot to understand the robotics platform and generate accurate robot control code directly—dramatically reducing the need for manually written glue code.
Through our developer community, we’re also building an open robotics ecosystem where developers can share ideas, collaborate, and shape what comes next. More software and hardware ecosystem support is on the way. Stay tuned.
